Sunfounder
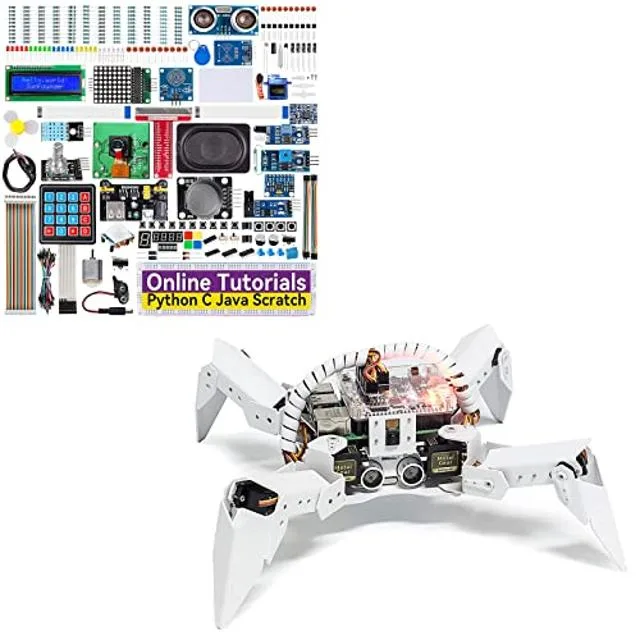
Sunfounder Raspberry Pi Ultimate Kit with PiCrawler AI Robot 337 components 131 projects
$174.99
0.00207622BTC
In stockWe take cryptocurrency — so the coins you hold can buy real hardware.Pay in crypto, spend it on real hardware. Free insured shipping worldwide over $399. Plain, unbranded boxes, sent from Germany.Free insured shipping over $399. Your rate is locked for 30 minutes once checkout opens.Rate locked 30 minutes. Every item sealed, serial-checked and covered by a 24-month warranty.Sealed, 24-month warranty.


yahboom
Expansion board for Jetson Nano and Raspberry Pi adds a 9-axis IMU, four encoder-motor channels, servo outputs and multiple bus interfaces for ROS robot development
This expansion board adds motor control and sensor interfaces to Raspberry Pi Jetson series boards, Sunflower Pi and industrial control boards. It targets makers and developers building ROS-based mobile robots or robotic arms who need a single board to drive multiple actuators and read orientation data. The onboard STM32F103C8T6 core handles real-time peripheral tasks while the host computer runs higher-level navigation stacks.
The board replaces simpler motor hats that only drive one or two motors and lack integrated attitude sensing. The jump is worth it when a project requires four encoder motors, mixed servo types, CAN or SBUS communication, and a 9-axis IMU all at once. Builders staying with a single differential-drive chassis or without ROS middleware will not need this level of integration.
The board mounts on the 40-pin header of supported Jetson or Raspberry Pi units and exposes multiple power output headers for external modules. Driver routines written in STM32CubeIDE are provided for motor control, MPU9250 sensor fusion and communication interfaces. Common issues include matching logic-level voltages on the CAN and SBUS lines and ensuring the host supplies enough current for all connected actuators.
| CPU Type | Other |
|---|
It is compatible with Raspberry Pi Jetson series boards, Sunflower Pi, and industrial control development boards.
Load the STM32CubeIDE driver routines onto the microcontroller first, then attach the expansion board to the host development board.
Recalibrate after any physical shock to the robot or when the IMU begins reporting unexpected posture data.
New to this? Buying PC parts with Monero — what to check, what it costs to pay, and what is never asked for.
Also in this aisle
Same shelf, same checkout — eight coins and a 30-minute rate lock.
What you pay in, and what you read prices in.
Sent from your wallet at checkout
Display only — the catalogue is priced in USD
No currency matches that.
Pick the language the site speaks to you in.
No language matches that.
New here?
Already have one?
There is no automatic reset: this shop sends no mail, so there is no one-time link to ask for. Leave the address on the account and it gets picked up by hand.
Request noted
Nothing is on its way to your inbox — this shop sends no mail at all. Someone picks these up by hand.
Remembered it?